
Hardware referencePublished document
Model-specific datasheet
Aero H743 Flight Controller
AeroH7 datasheet · HW Rev 1.0 · Document Rev 1.0 · October 2026. Includes specifications, pinouts, wiring and integration guidance.
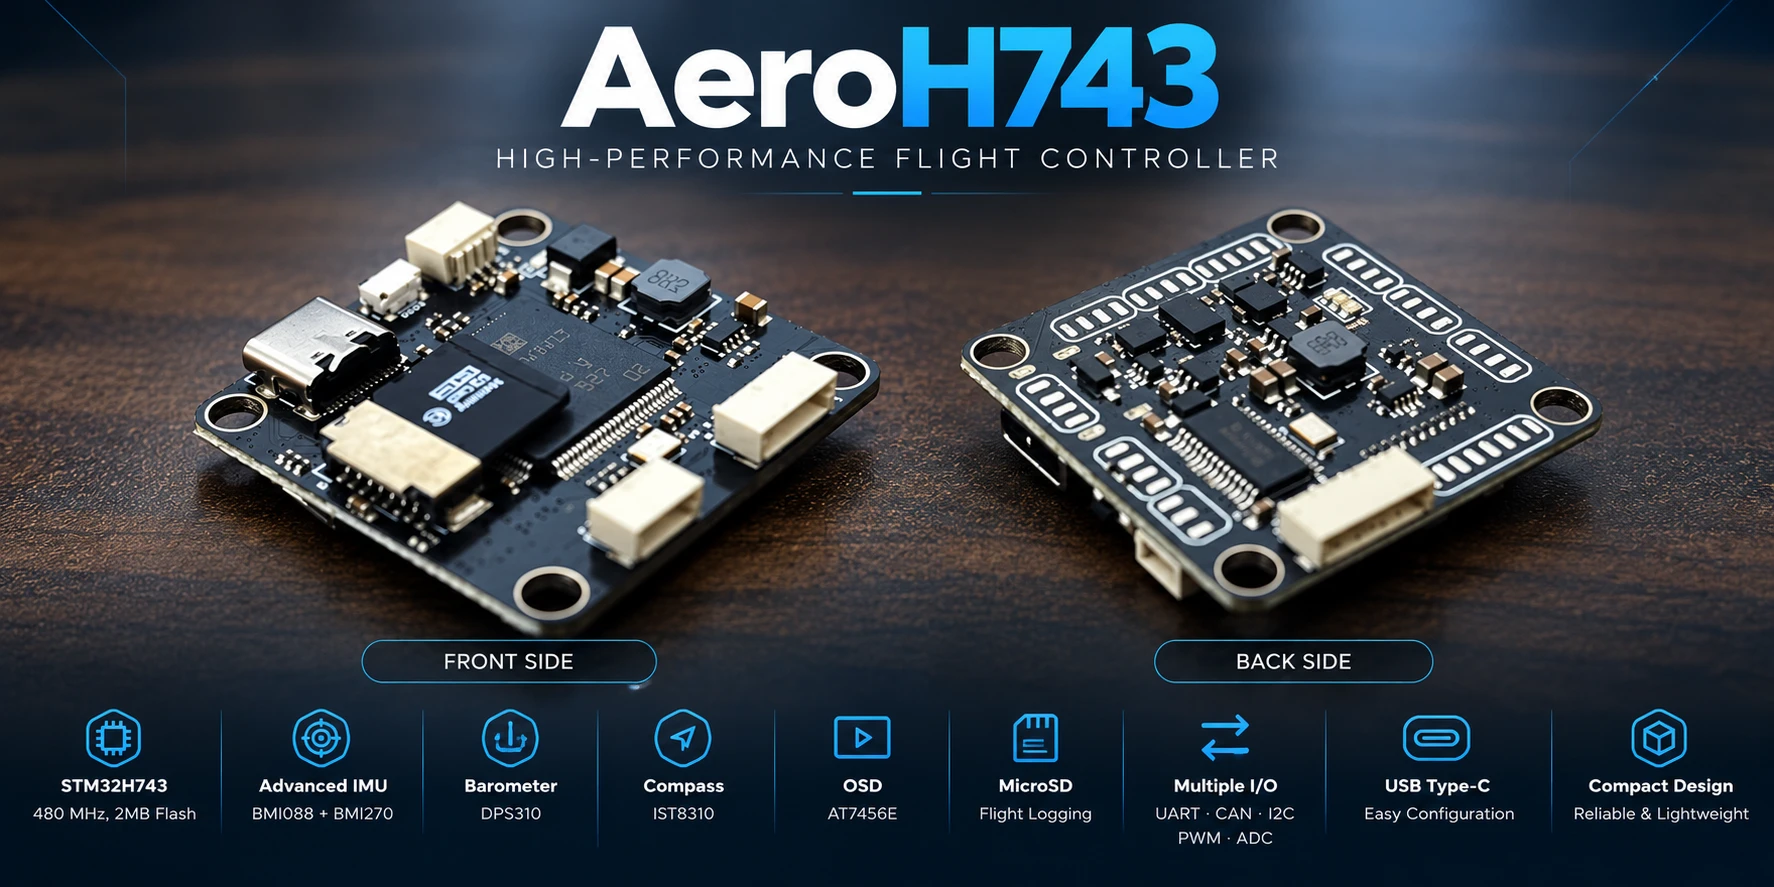
Front & back
Full imageThe Aero H743 Flight Controller is powered by the STM32H743 processor, with dual IMU sensors, multiple connectivity interfaces and flexible peripheral support for custom UAV development, FPV drones and professional drone applications. Supports ArduPilot, PX4, Betaflight and INAV.
SKUAERO-FC-H743-V1
Product price unavailable. Refresh availability to retry.
Shipping included. 5% GST extra · HSN 88073020. Final total is shown at checkout.
Flight controllers manage how drones move. Explore flight-control electronics for your drone platform.
A flight controller that processes sensor information and controls a drone’s flight, with support for ArduPilot and PX4.
STM32H743 processor
STM32H743 processor for flight-control computation.
BMI088 + BMI270
Two IMU sensors measure movement and orientation.
Flight data, recorded
MicroSD logging records flight data for review.
UART · CAN · I²C
UART, CAN and I²C connections support peripheral integration.
Clean output · precision sensing
Low-noise sensors provide clean output for flight-control sensing.
Board construction
High-quality PCB construction for flight-control electronics.
Multi-layer PCBA protection
Conformal coating provides a multi-layer protective barrier on the PCBA.
Versatile applications
Multiple outputs support a range of drone-system applications.
PWM level output
Supports 3.3V and 5V PWM level output.
Technical specifications for Aero H743 Flight Controller.
| Processor | STM32H743VIT6 |
|---|---|
| Processor speed | Arm Cortex-M7 · 480 MHz |
| Flash memory | 2 MB |
| IMU sensors | BMI088 + BMI270 |
| Barometer | DPS310 · 300–1200 hPa |
| Compass | IST8310 · ±1600 µT (X/Y), ±2500 µT (Z) |
| OSD | AT7456E · MAX7456 compatible |
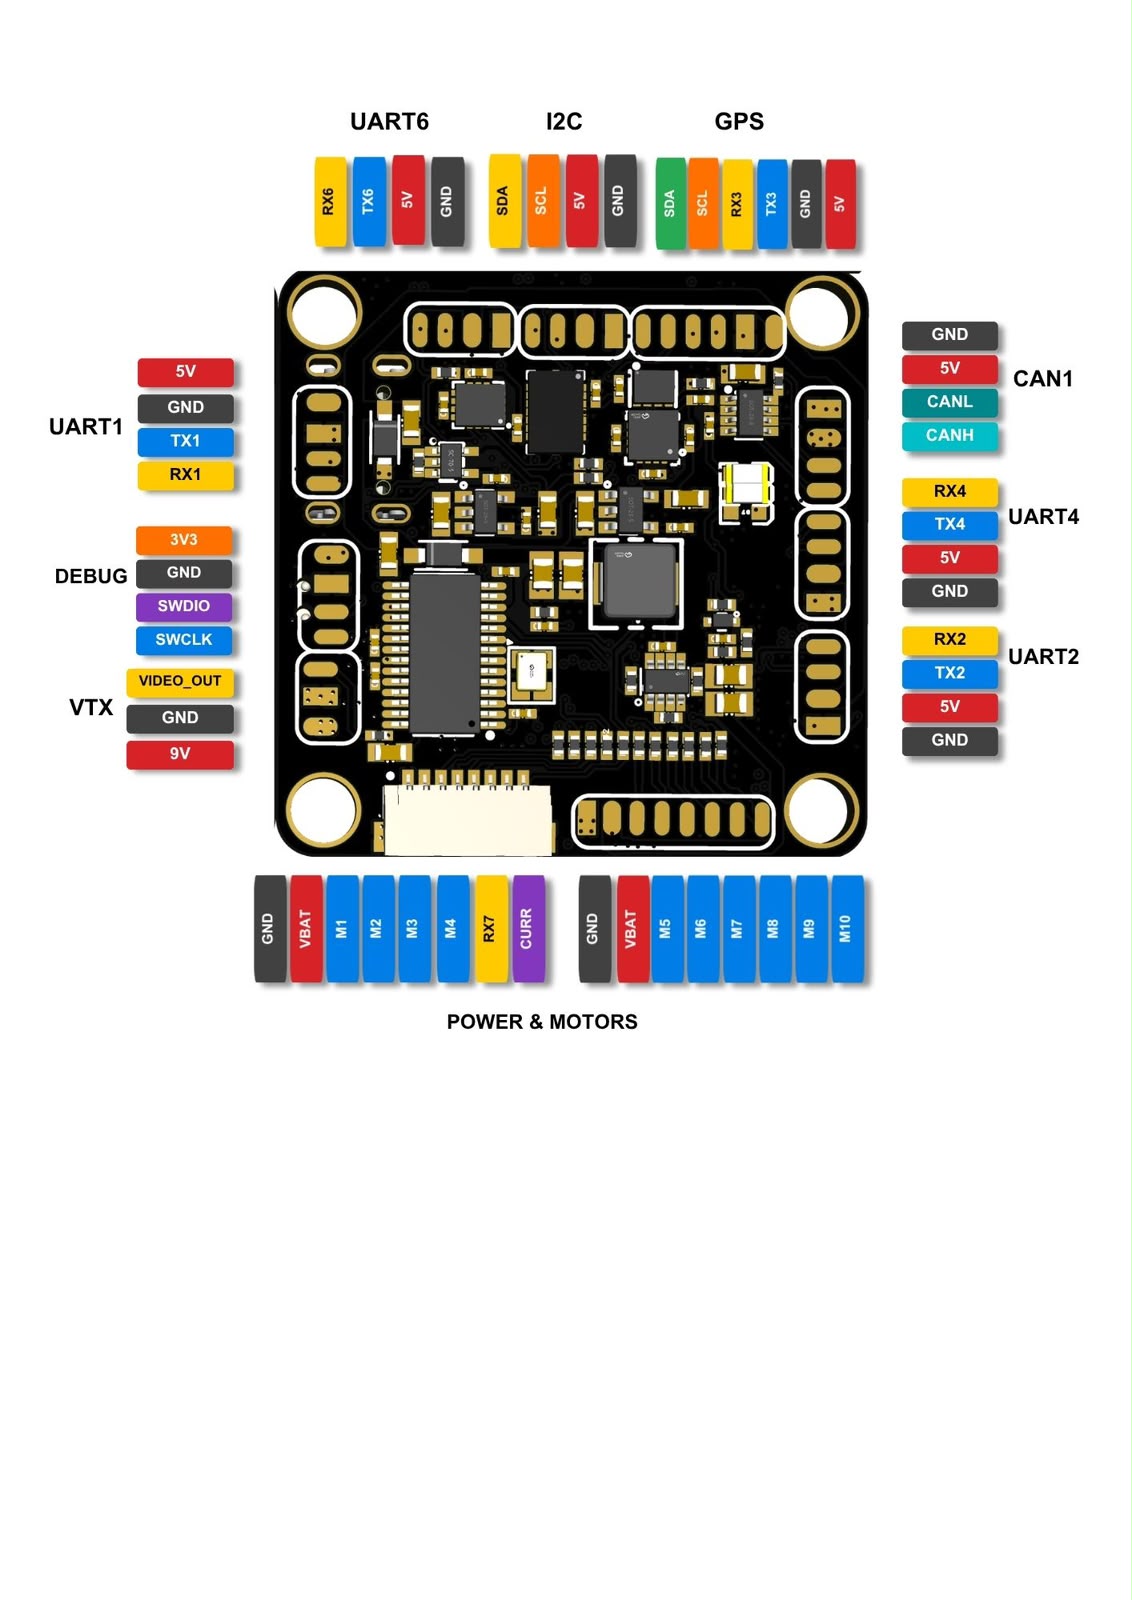
| UART ports | 6 full (1, 2, 3, 4, 6, 8) + UART7 RX-only ESC telemetry · 3.3 V logic |
| Motor / servo outputs | 10 (M1–M10) · DShot on all; bidirectional DShot on M1–M8, not PX4 / INAV |
| Output protocol groups | M1–4 / M5–6 / M7–10 |
| CAN interface | 1 × CAN1 · DroneCAN capable, firmware dependent |
| I²C interface | 1 external I2C1 bus · shared by I²C and GPS connectors |
| GPS connector | UART3 + I²C |
| RC input | UART6 (CRSF / ELRS) · SBUS hardware-inverted onto RX6 |
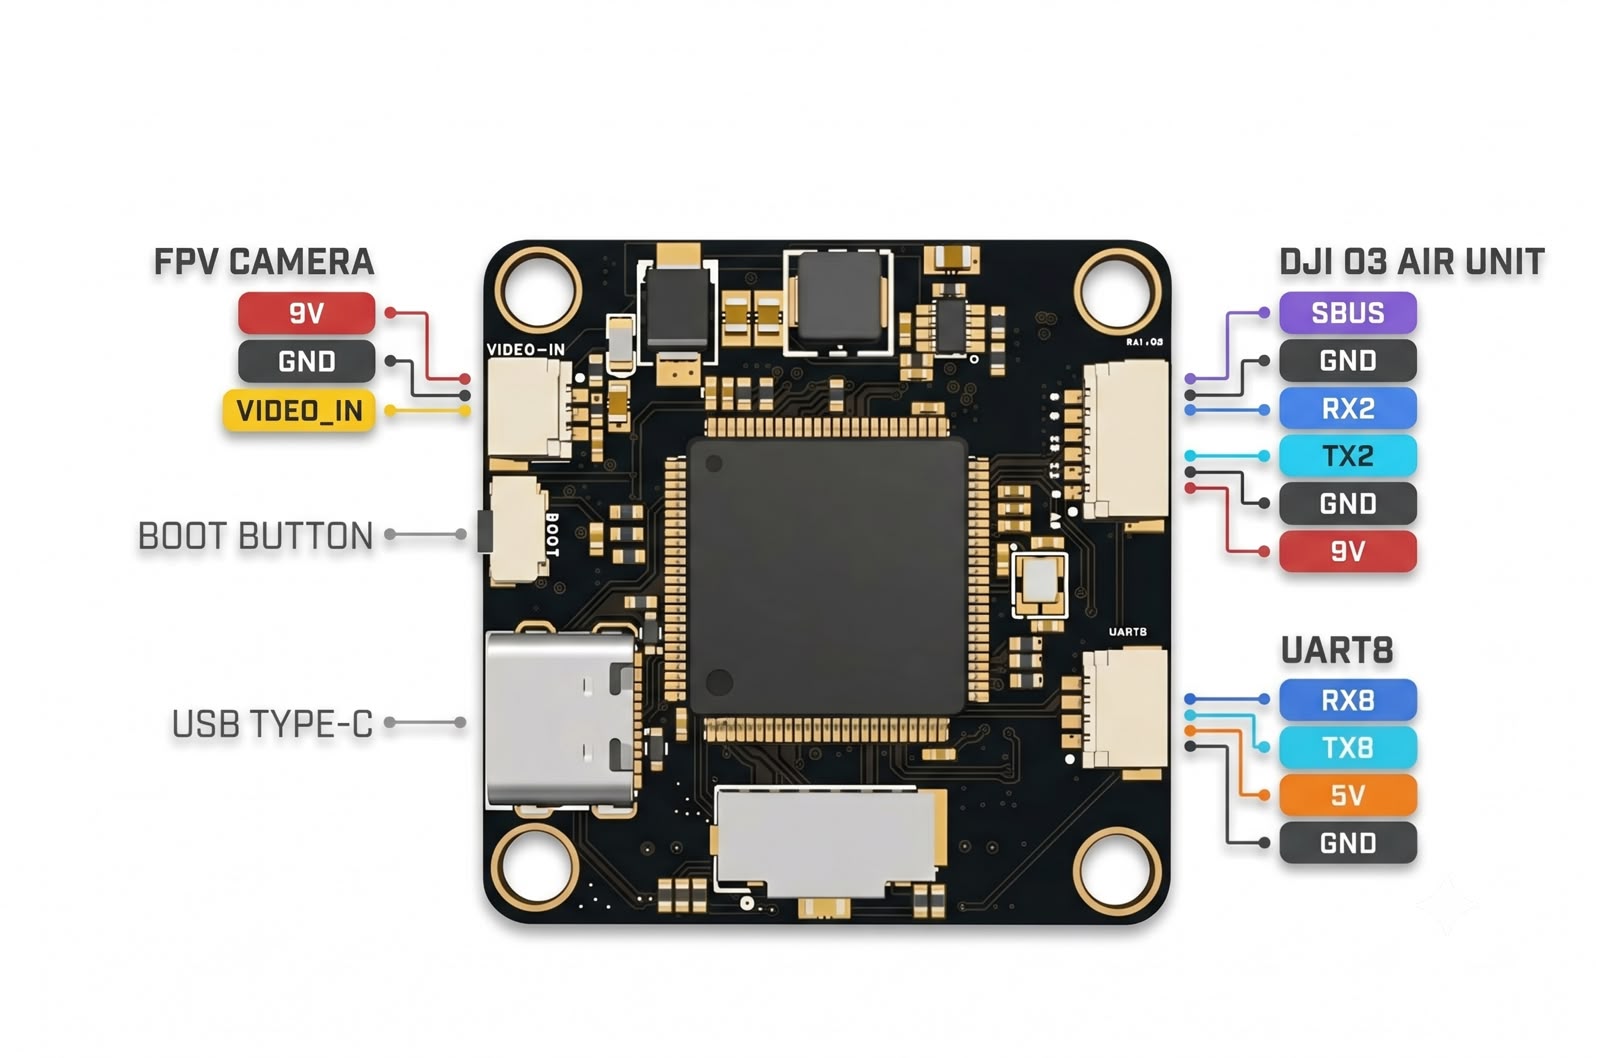
| Digital video | DJI O3 / O4 · UART2 + SBUS + 9 V |
| Analog video | VIDEO_IN camera input → VIDEO_OUT VTX output |
| Debug | SWD: 3V3, GND, SWDIO, SWCLK · BOOT button |
|---|---|
| ADC monitoring | Dedicated VBAT voltage and CURR external ESC current-sense inputs |
| Input power | 2S–6S LiPo, 6–27 V |
| 5 V BEC output | 5 V / 3 A design rating · shared system rail |
| 9 V BEC output | 9 V / 3 A design rating · shared video rail |
| Logging | MicroSD black-box · FAT32 |
| USB | Type-C · configuration, firmware, MAVLink |
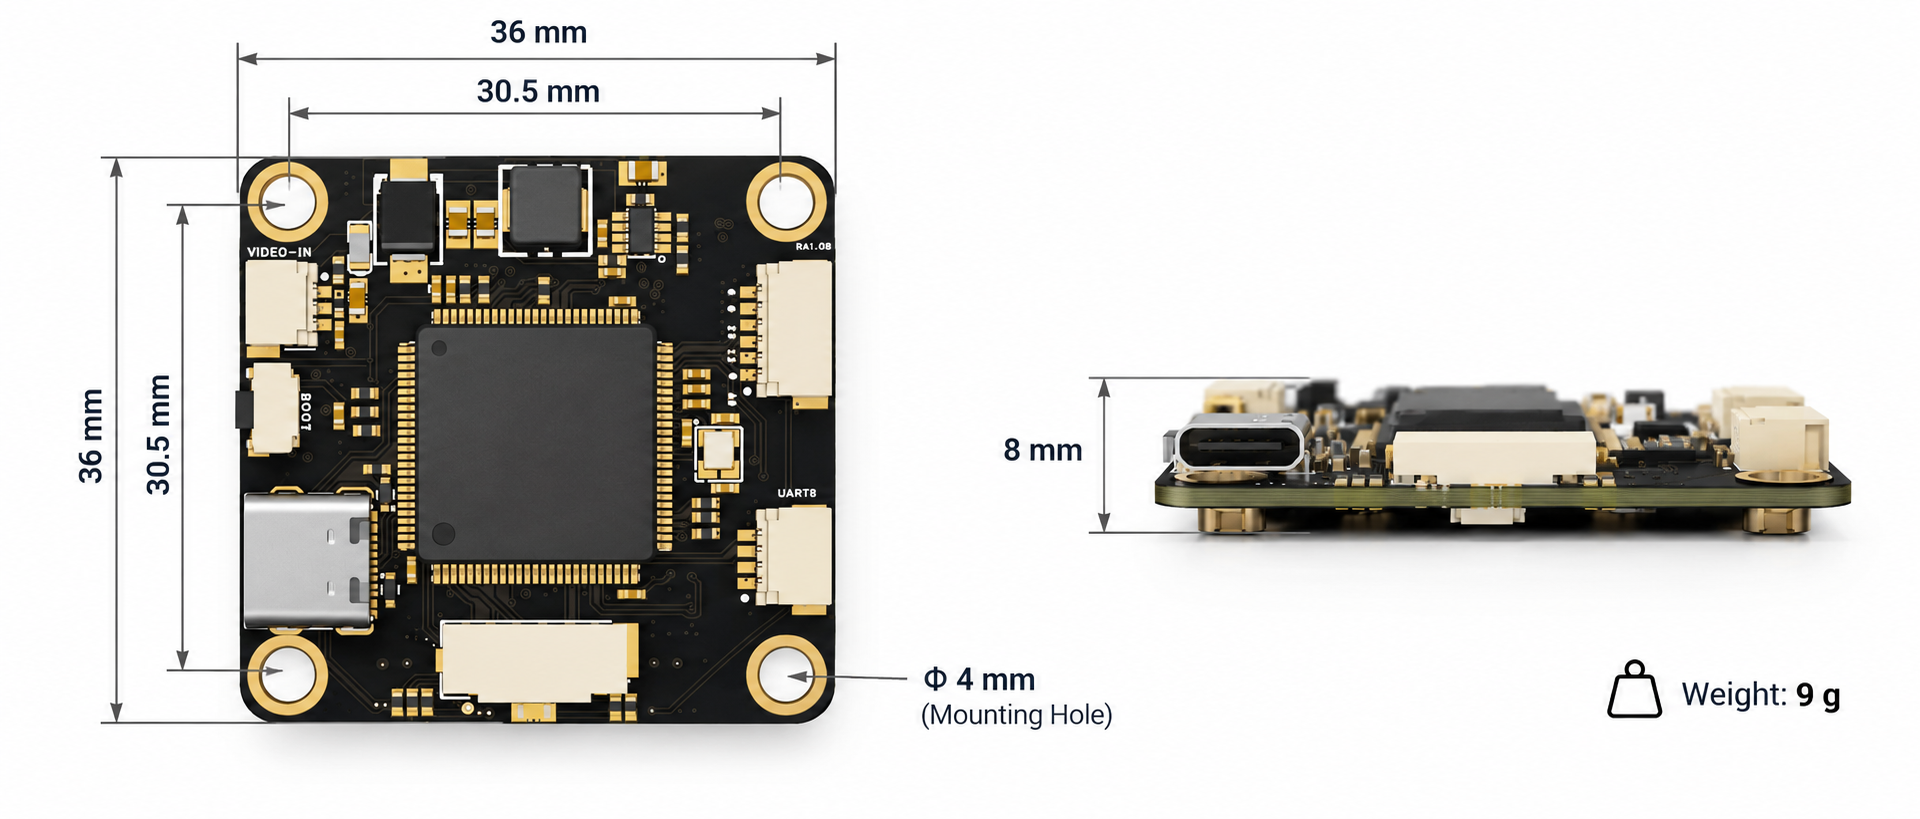
| Dimensions | 36 × 36 × 8 mm |
| Mounting | 30.5 × 30.5 mm · 4 × Ø4 mm holes |
| Weight | 9 g |
| Connector variants | A: locking JST-GH 1.25 mm · B: solder pads; 8-pin JST power/motor connector retained |
| Status LED | RGB |
| ArduPilot | 4.6.0+ · analog OSD, DisplayPort, bidirectional DShot M1–M8 |
| Betaflight | 4.5.0+ · bidirectional DShot via bitbang |
| INAV | 8.0.0+ · no bidirectional DShot |
| PX4 | 1.16.0+ · no analog OSD or bidirectional DShot |
Connector and pinout diagrams for this model. Open the full-size images to read the labels.
STEP file coming soon. Contact us for mechanical integration details.
AeroH7 datasheet · HW Rev 1.0 · Document Rev 1.0 · October 2026. Includes specifications, pinouts, wiring and integration guidance.
Firmware downloads are not available. Contact our team for target-specific support.